Camera-tracked
robotic hand
In development · Not yet builtA robotic hand intended to mirror finger movements captured by a laptop camera. The project brings together hand-pose tracking, a live computer visualization, and a printable hand-and-forearm assembly.
Engineering notes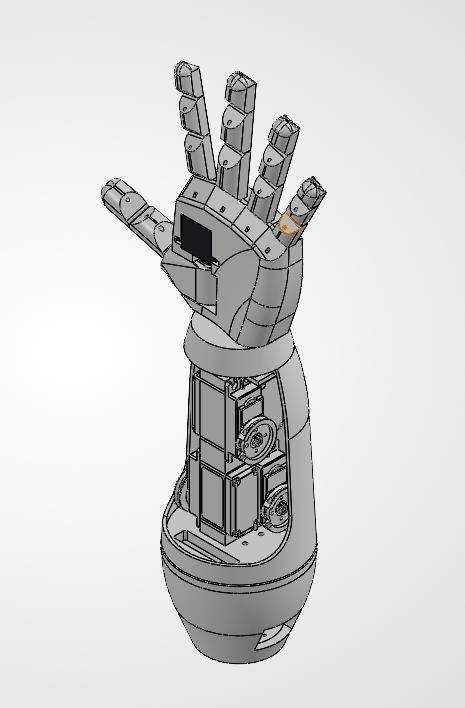
Engineering notes
DESIGN → INTEGRATION → TESTThe approach
Handlink estimates hand landmarks from the camera, calibrates an open hand and a fist, and smooths five finger-bend signals. A live skeleton provides visual feedback before hardware integration.
Current work
Offline tracking software, CAD assemblies, a 26-part print checklist, and assembly documentation are available. The mechanical model reproduces an existing humanoid-hand design; the project focus is camera tracking and control integration.
What comes next
Resolve servo fit conflicts, confirm the electronics, print and assemble the mechanism, and develop the motor-control connection. Physical tracking and actuation performance remain to be measured.
Handlink currently produces simulated control setpoints. It does not yet send commands to physical motors or track thumb opposition.
Hand tracking in action
A recorded demonstration of Handlink tracking hand movements from the laptop camera and displaying a live hand skeleton and finger-bend readings. Physical robotic-hand control is still in development.
Intended system architecture
- CameraHand movement
- Hand trackingLandmarks & calibration
- Finger setpointsSmoothing & visualization
- Motor controllerPlanned integration
- Robotic handPhysical build pending
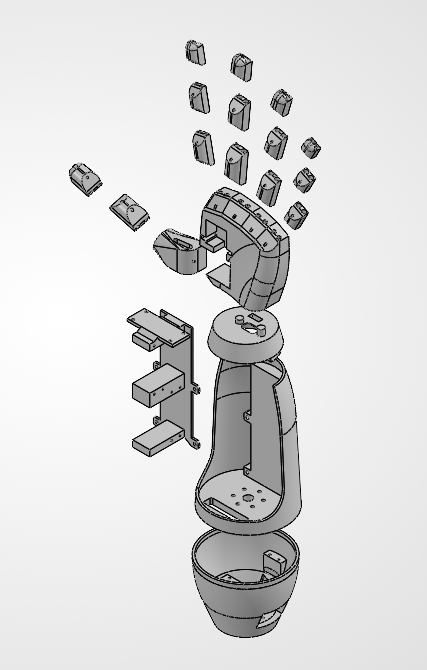
From CAD to the workbench.
Physical build photos will be added here after fabrication and assembly.
Photos pendingNext: the physical hand.
A demonstration of the assembled robotic hand responding to camera tracking will be added after hardware integration.
Hardware demo pending